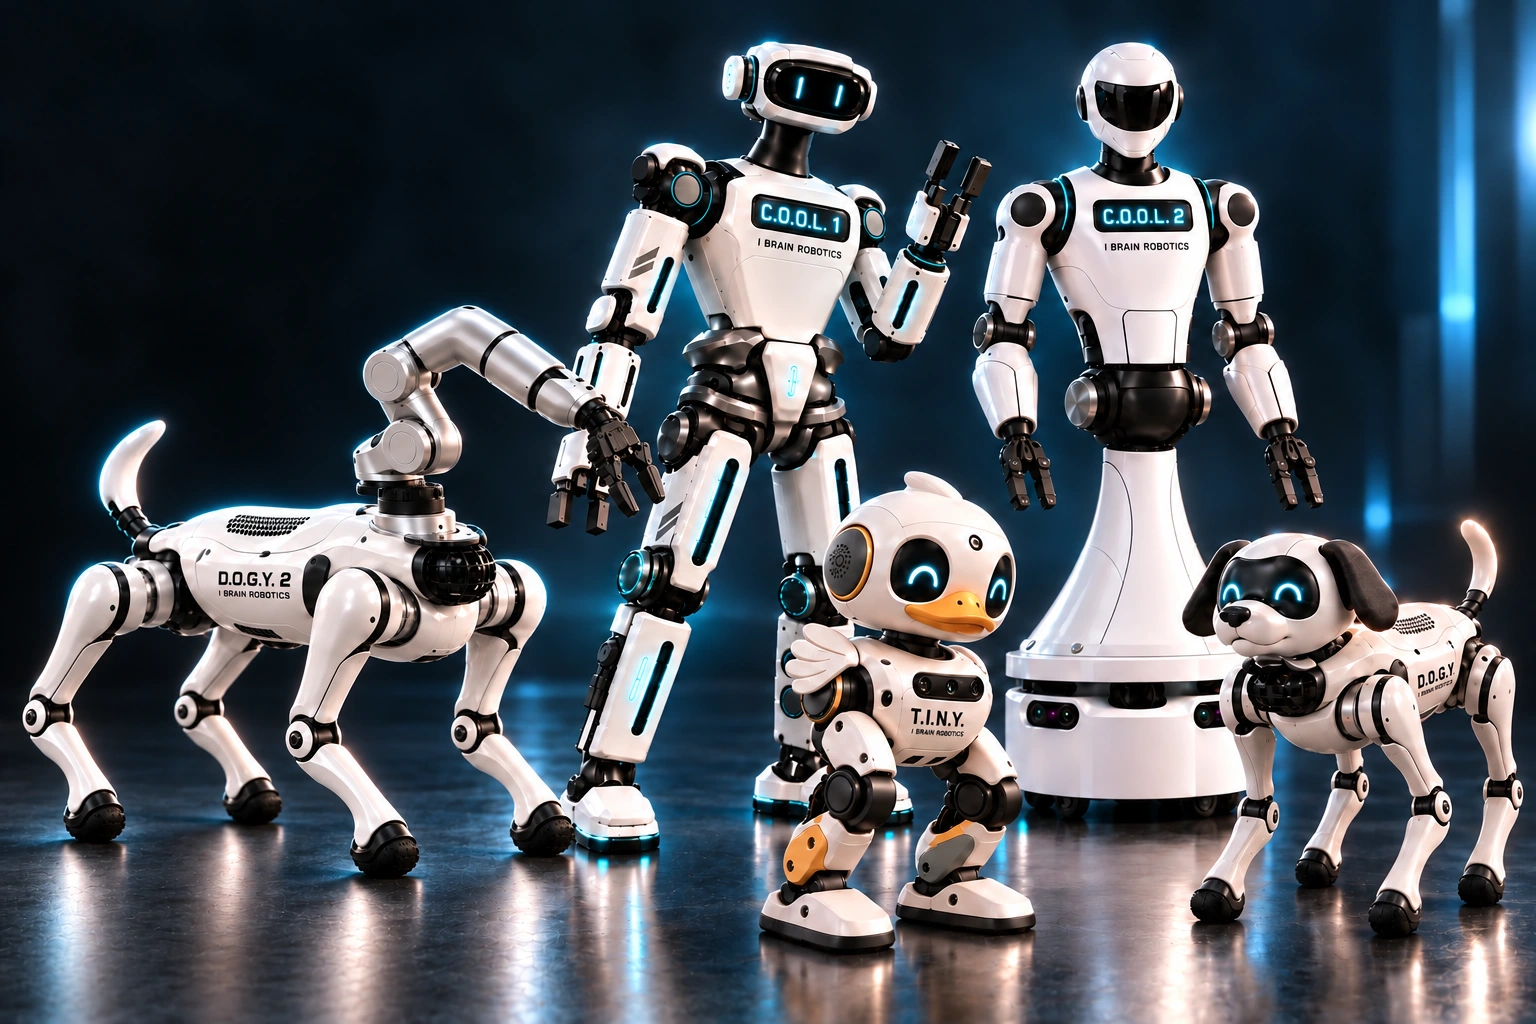
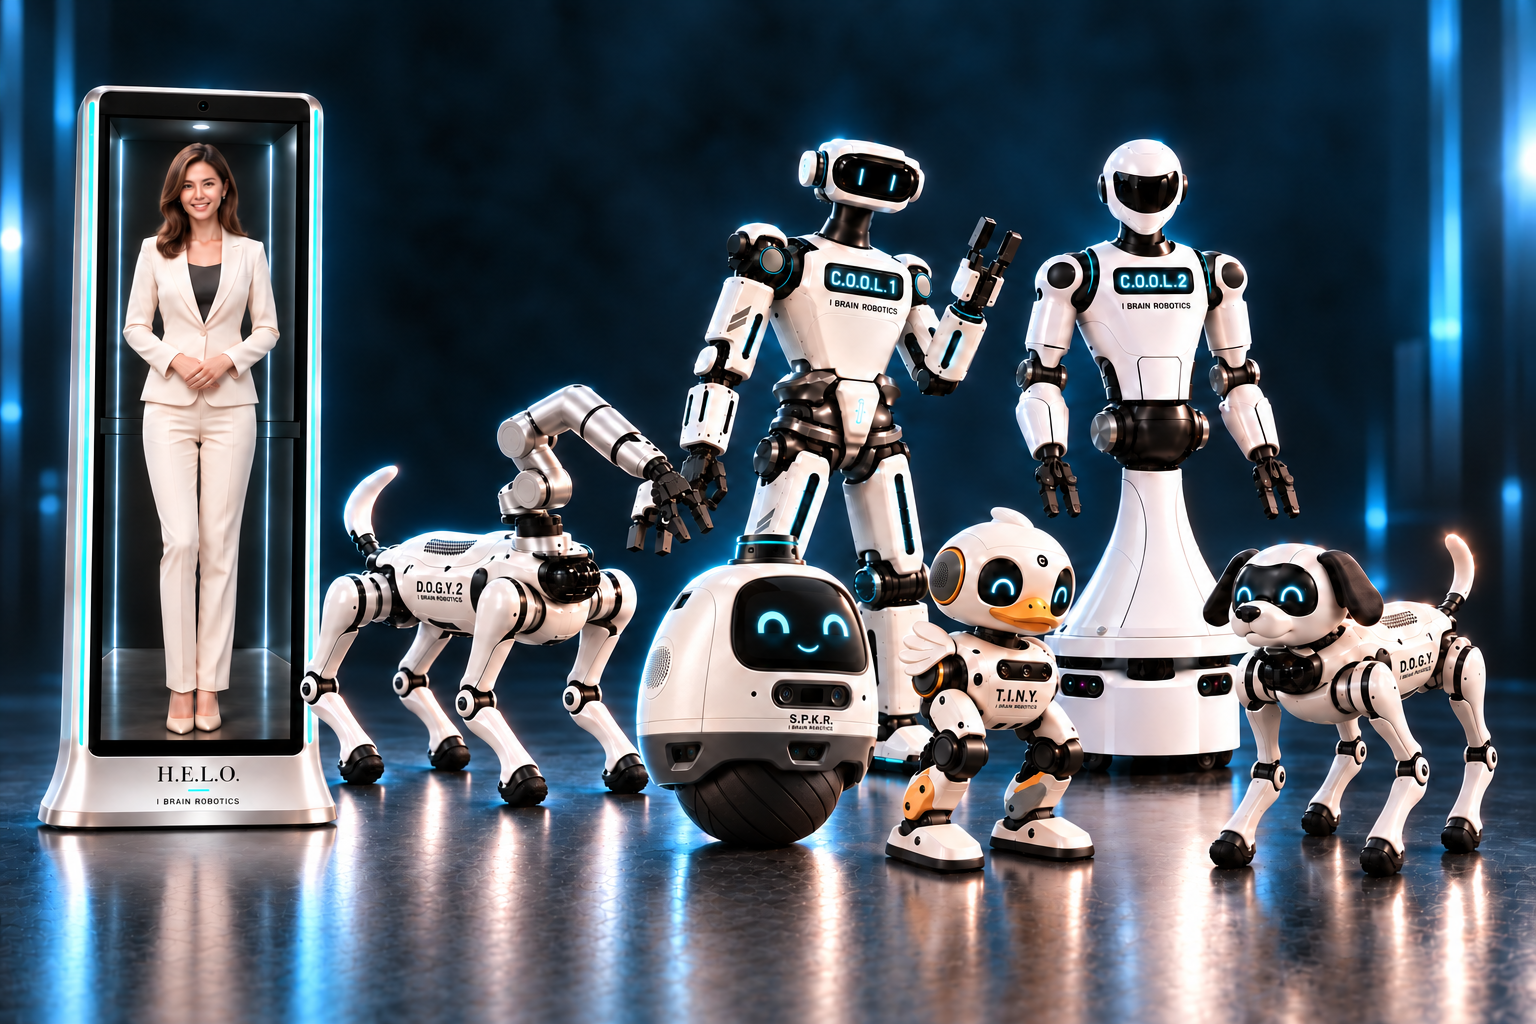
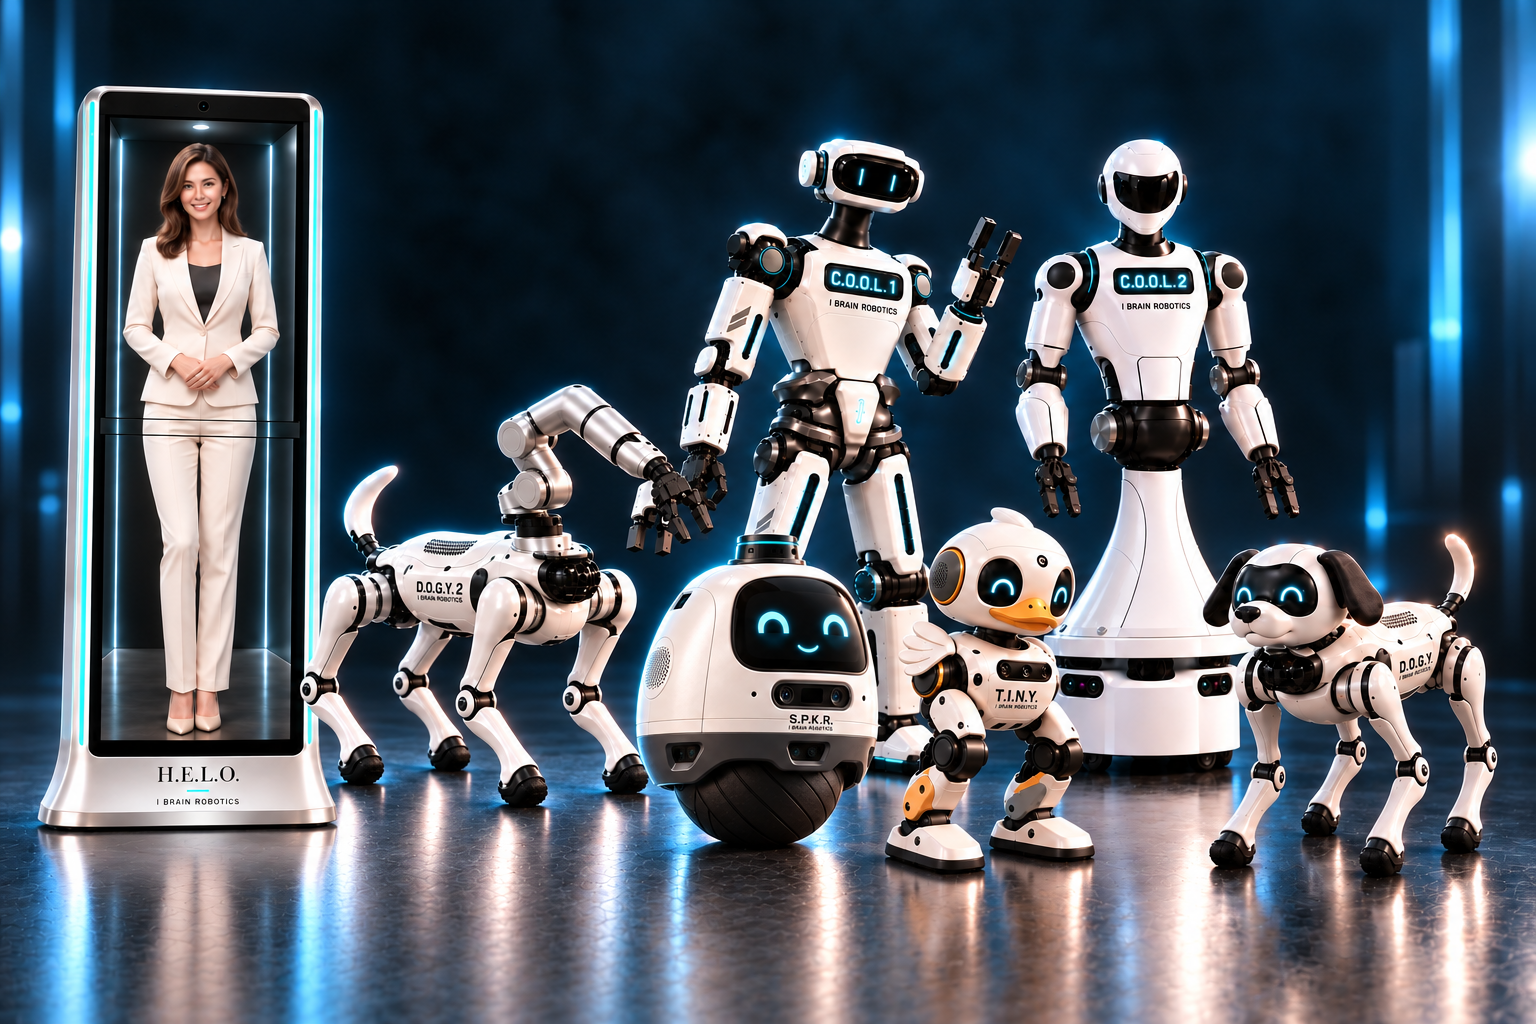
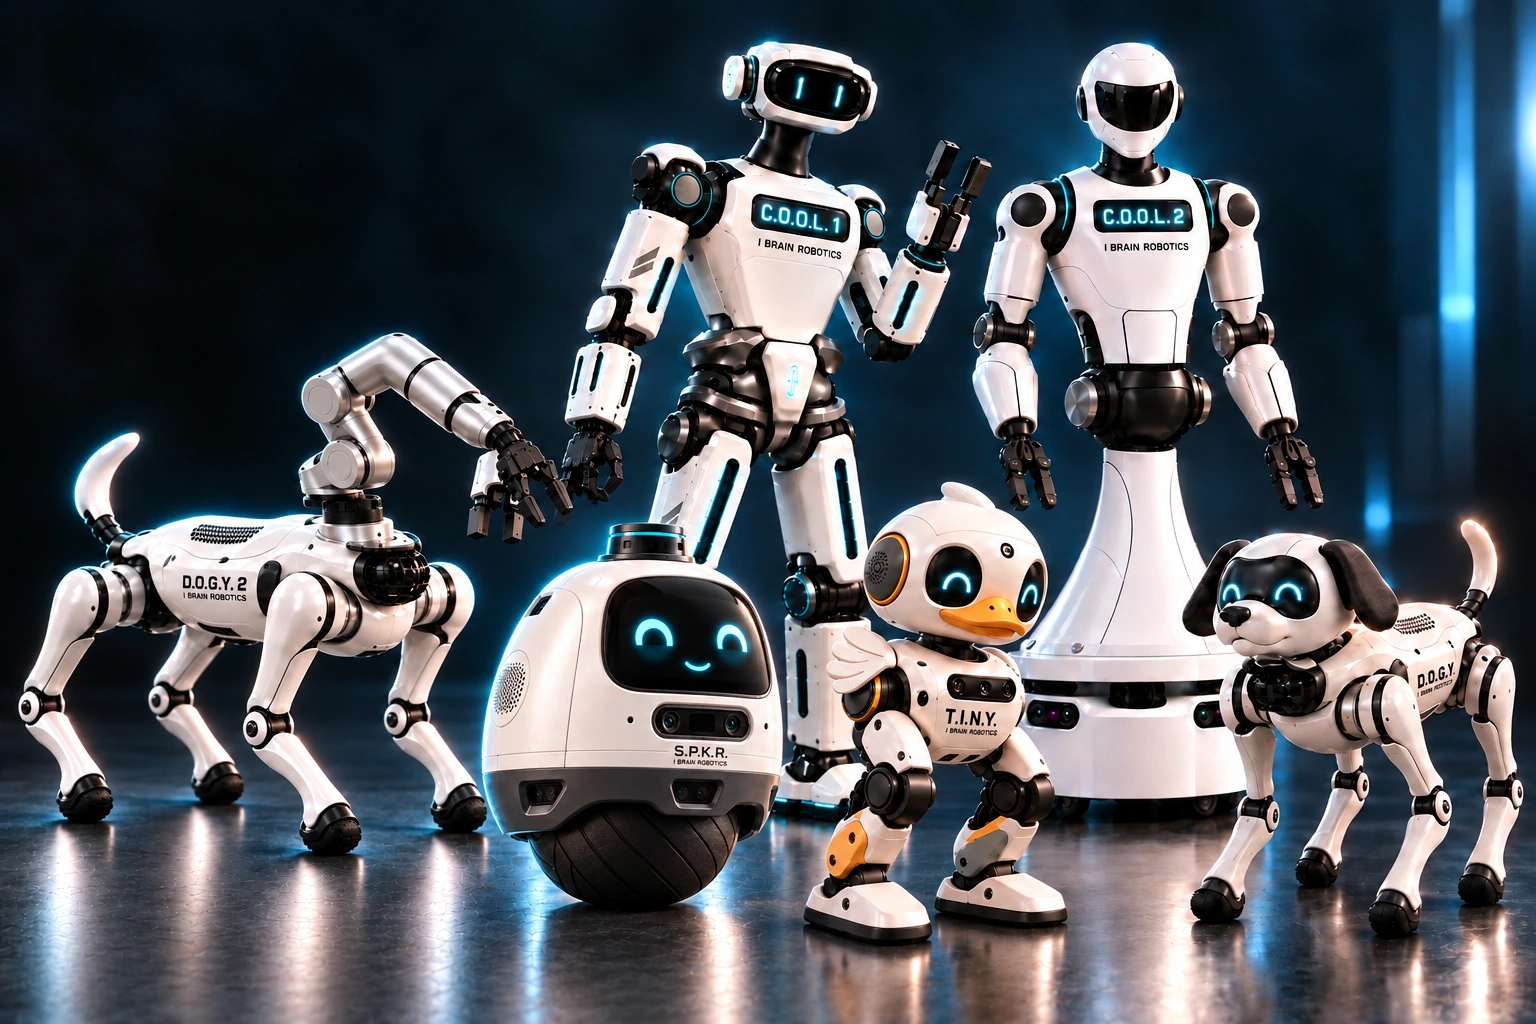
A face you can connect with
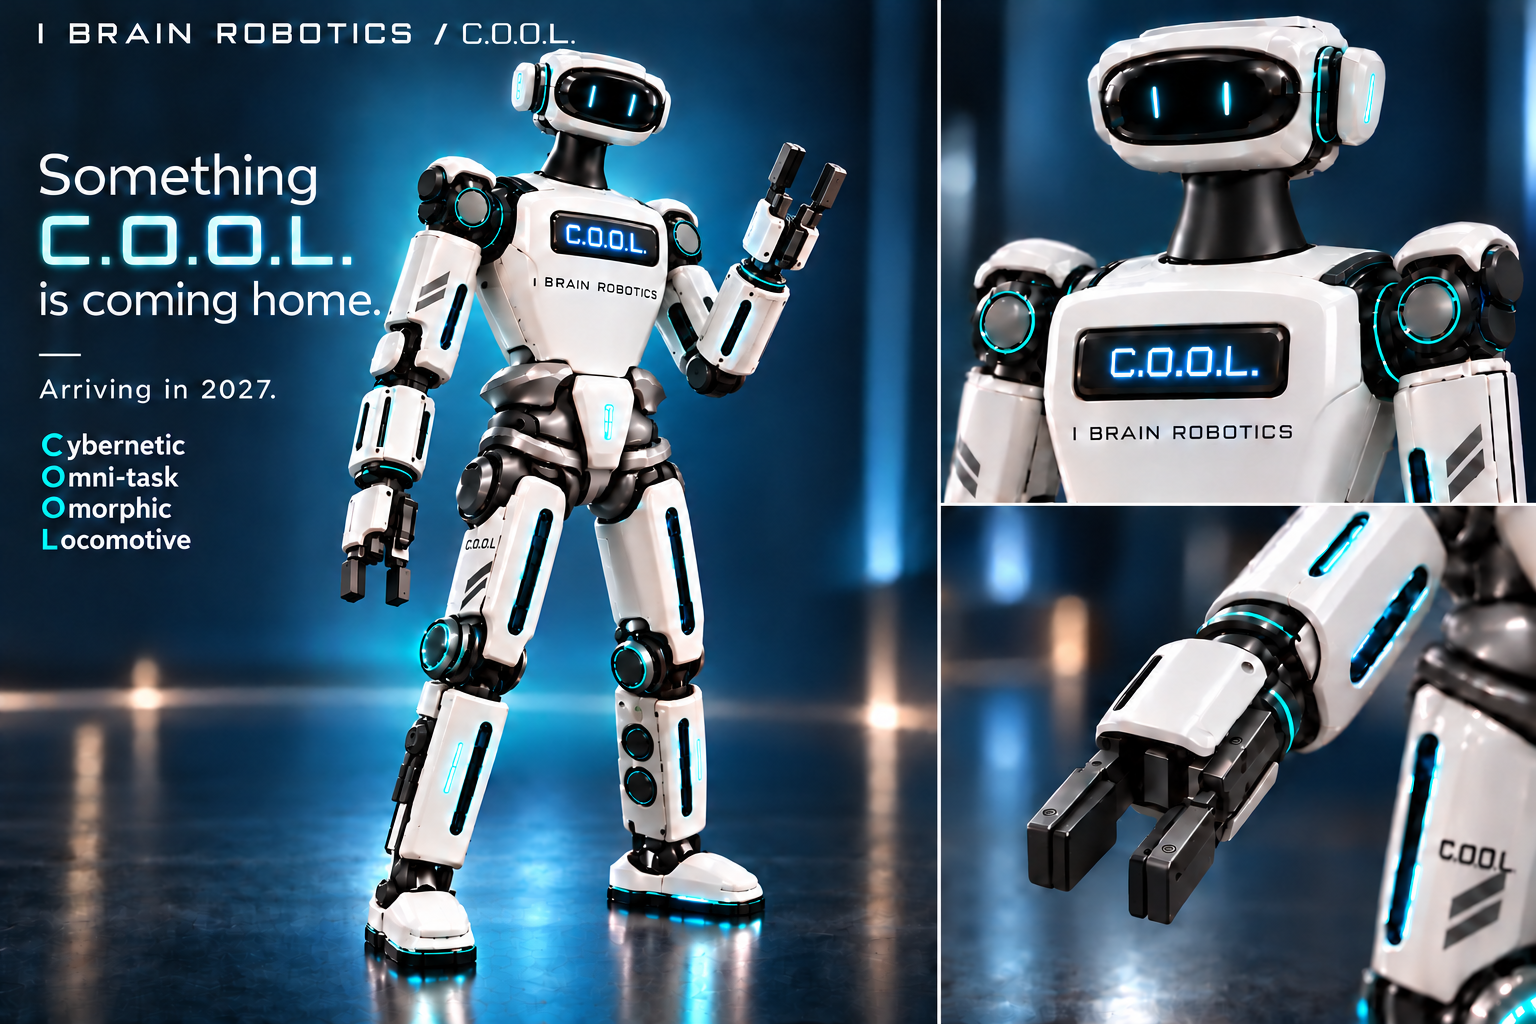
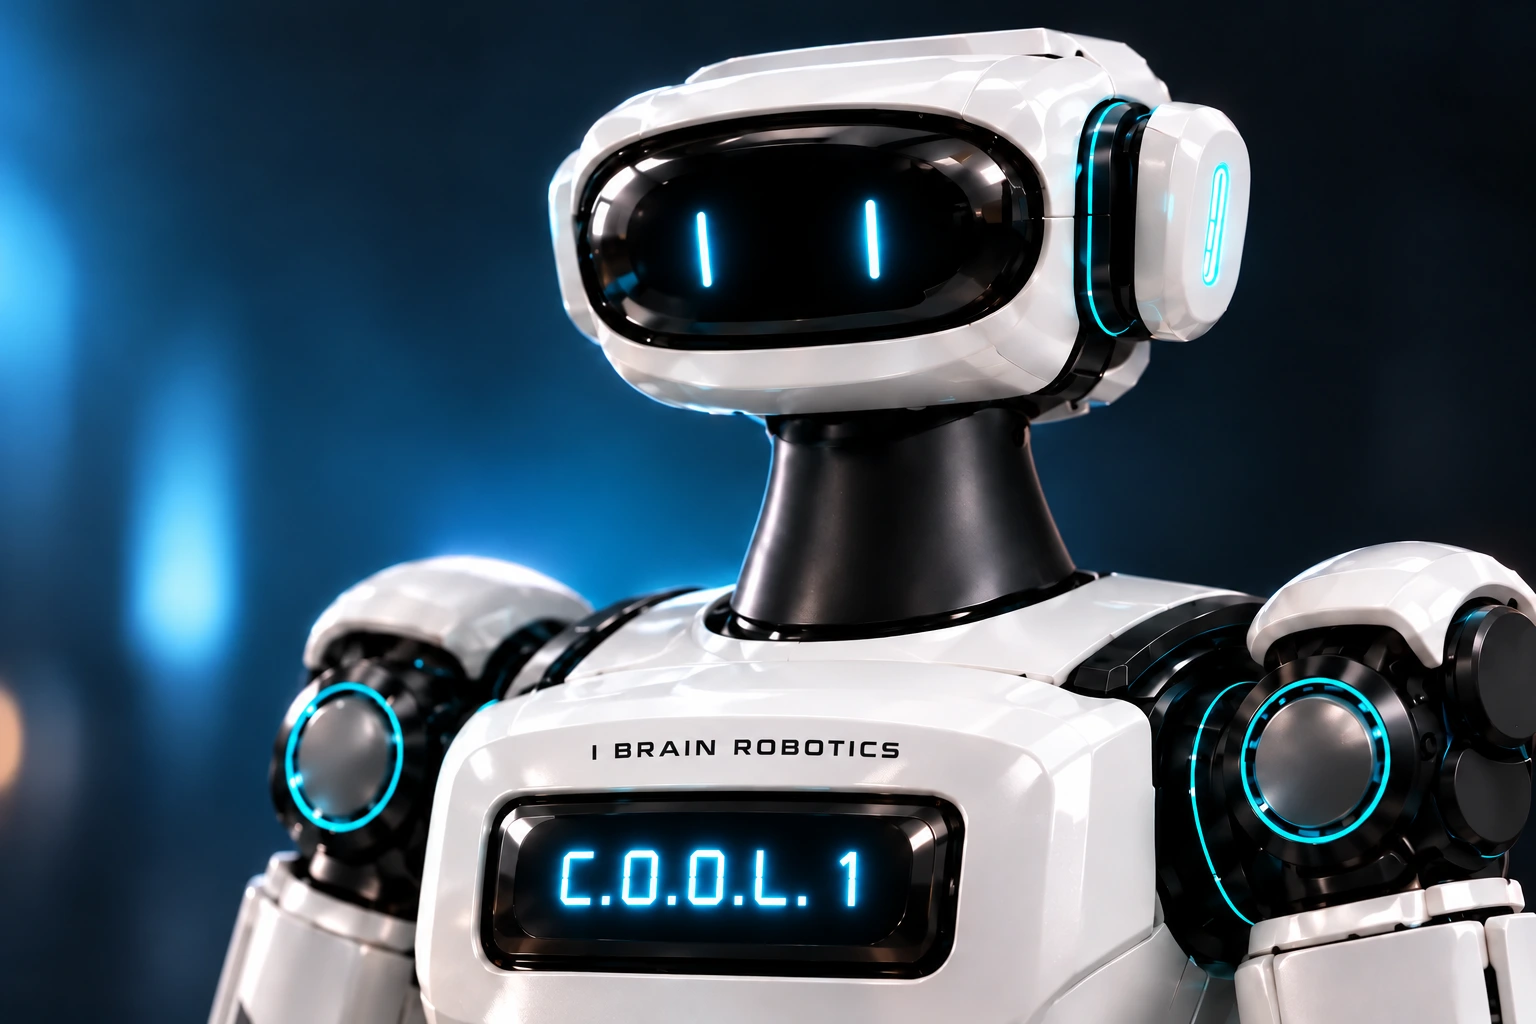
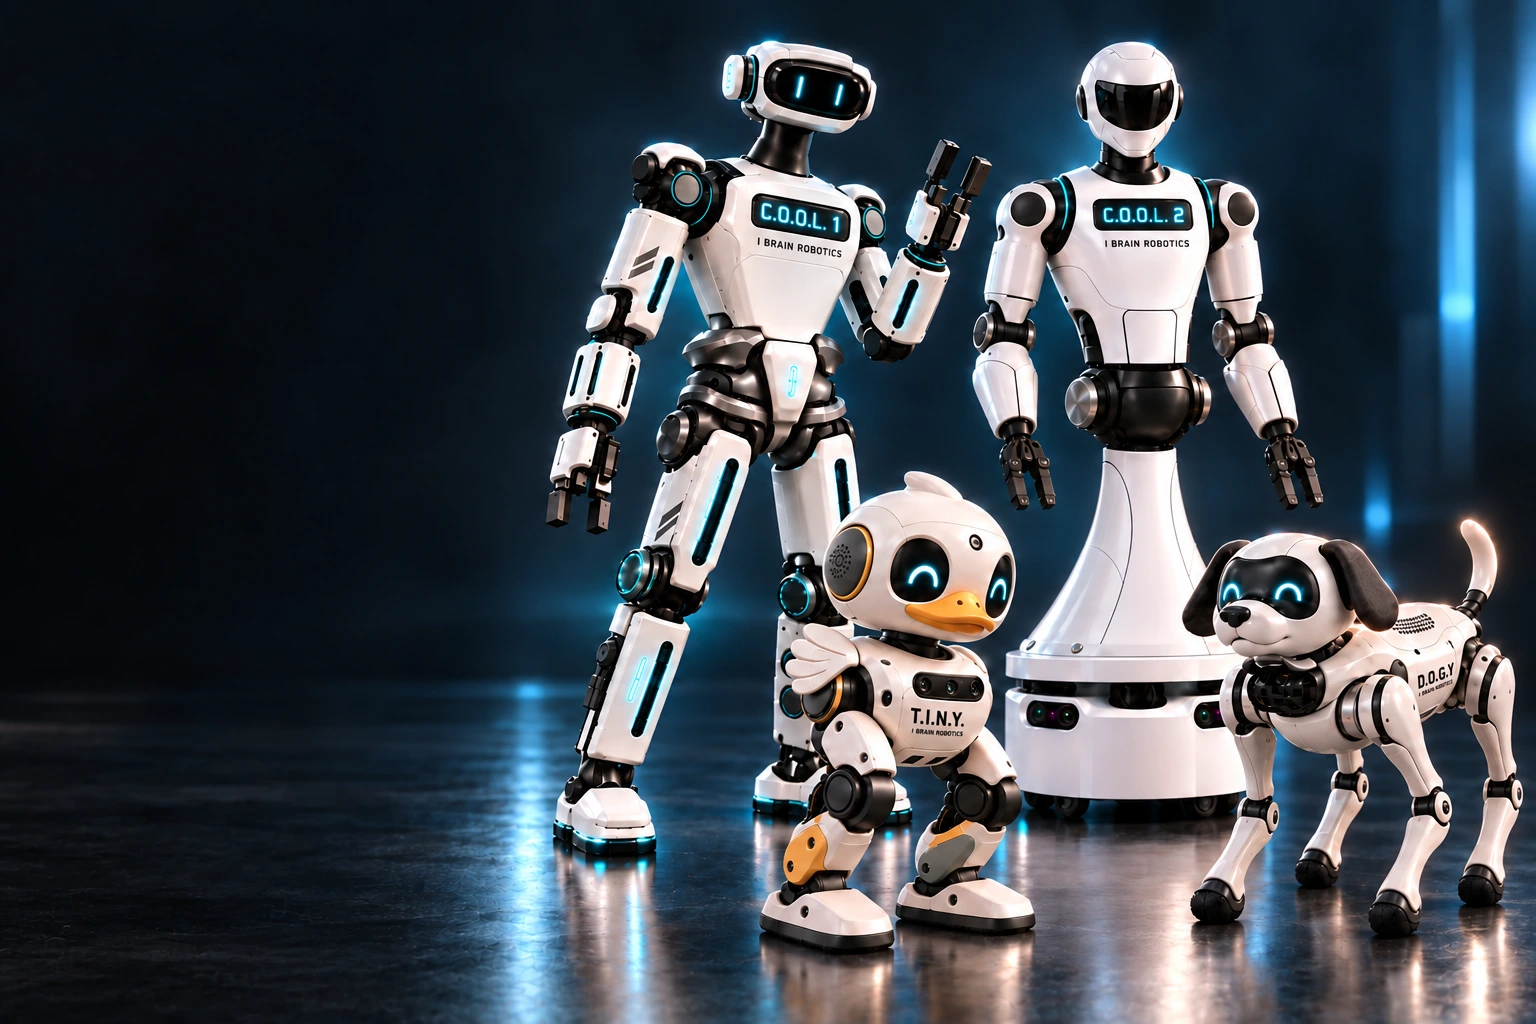
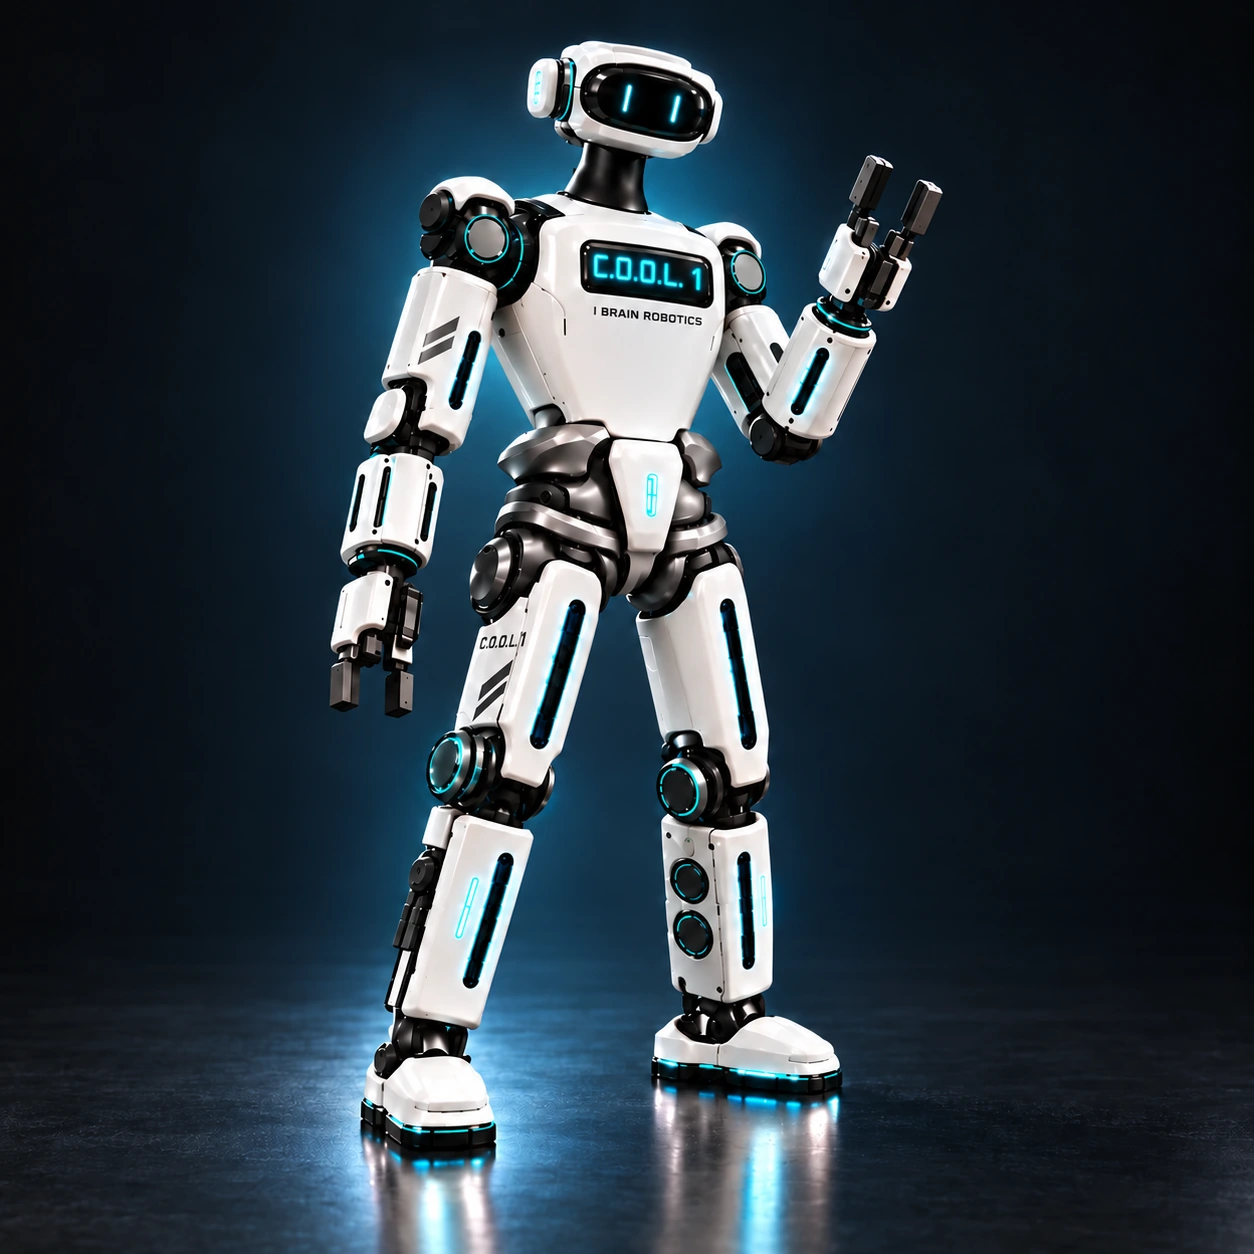
A polished black face panel and clear cyan eyes give the head a recognizable expression. The clean shell replaces visual clutter with a purposeful, approachable character.
 Book a Demo
C.O.O.L. 1
Cybernetic Omni-task Omorphic Locomotive
A full-body humanoid with an expressive face, articulated arms and a distinctly approachable presence. C.O.O.L. 1 brings our companion-first design language to a bipedal robotics platform.
 I BRAIN ROBOTICS / C.O.O.L. 1
C.O.O.L. 1 has a character of its own.
Discover what makes it unmistakable.
Hardware foundations and a clear development direction, brought together in one robot.
Upstream walking and running development stack
Expressive face and companion-focused identity
Gripper-based task development
Navigation integrated with perception and operating limits
Explore the intended applications.
Help shape a pilot around your space and goals.
A platform for teams exploring bipedal motion, human–robot interaction and supervised manipulation workflows.
Discuss this applicationA distinctive humanoid presence for guided demonstrations, product launches and carefully controlled visitor experiences.
Discuss this applicationA development direction centered on conversation, presence and purposeful assistance. Specific household tasks will be introduced only after testing.
Discuss this applicationApplication concepts describe intended uses. Supported tasks and operating environments will be defined through validation.
The technical foundation is the open-source RoboParty Roboto Origin project. Published platform capabilities describe the underlying research robot; the I Brain shell, head, hands and software require integration and validation.
| Specification | Detail | Basis |
|---|---|---|
| Base platform | RoboParty Roboto Origin | Platform reference |
| Reference height | 1.25 m / 49.2 in | Unmodified Roboto Origin |
| Reference weight | Approximately 34 kg / 75 lb | Unmodified Roboto Origin |
| Reference degrees of freedom | 23 | Unmodified Roboto Origin |
| Reported running speed | 3 m/s / 6.7 mph | Upstream prototype demonstration |
| Locomotion | Two articulated legs | Design architecture |
| Upper body | Two articulated arms and an expressive head | Design architecture |
| End effectors | Compact parallel grippers shown | Design direction |
| Exterior | Segmented pearl-white shell, dark joints, cyan accents | Design direction |
| Control foundation | ROS 2 deployment framework | Published platform |
| Training foundation | IsaacLab training; MuJoCo simulation transfer | Published platform |
| Robot models | URDF / MJCF descriptions | Published platform |
| Navigation | Localization and navigation experiment modules available upstream | Published platform |
| Final height & weight | Measured after shell, head and gripper integration | Validation pending |
| Battery, speed & payload | Final configuration and operating limits to be released | Validation pending |
| Availability | 2027 target; pricing not announced | Program target |
C.O.O.L. 1 is in development. The current work combines a bipedal hardware foundation with I Brain’s exterior and interaction direction. A validated task list will accompany the production configuration.
Parallel grippers are part of the current design. Usable objects, reach, grip force and carrying capacity depend on the final arm and gripper integration and will be tested before being advertised.
Two legs create a recognizably human silhouette and a platform for legged-motion research. Successful movement on the original platform does not automatically establish safe operation with new covers, hands and head components.
Follow its development or tell us about the experience you want to create.
No payment or reservation required.